mardi 31 décembre 2019

Types of speed reducers and gear stepper motors

If we focus on their internal disposition, we can classify motor speed reducers as follows:

Planetary speed reducers
Planetary gearbox stepper motors are arranged into stages, each one having the following structure:

Sun, the central gear. It rotates around the central shaft of the system
Carrier, which holds up to 3 gears and meshes with the Sun
Ring gear, that engages with the satellites
The central shaft can also be used as a center of rotation, making it easy to switch directions.

This type of gear motor is highly reliable. It is for this reason that it is used in many automatic transmissions. In addition, it is quite versatile, which makes it ideal for many sectors – from industrial automation to robotics.


Among the advantages of planetary gear motors we can find:
Their great angular rotational stability and, therefore, their high level of precision.
Their limited vibrations when dealing with various loads
Their uniform transmission capabilities allow for a greater repeatability
One must also keep in mind that these motor speed reducers have a higher contact surface. This means that they engage more smoothly and generate lower noise levels.

This better engagement and a good torsional rigidity make this type of speed reducer more durable.Among the many types of speed reducers and gear motors, their planetary variant are more durable.(stepper precision planetary gearbox)


Worm drive
This type of industrial gear motor is simpler, since it transmits the motion of a worm wheel using an inline worm screw along its shaft.

The resulting gear ratio is calculated based on the number of teeth of the crown wheel and the indentations of the worm.

One of its greatest advantages is that it offers a high reduction with few stages, which would require several speed reductions when using conventional gears.

https://nema42motor.blogfree.net/?t=6111055
https://www.smore.com/j9fhd-stepper-articles

jeudi 26 décembre 2019

What’s the Good Point of Oyosteppers’ Linear Stepper Motors?

With the development of science and technology, automation has been applied more and more in industry. When designing automation equipment, various factors must be considered, including production line layout, installation environment, easy maintenance, transmission accuracy, wiring configuration, control system, etc. This means that it takes a lot of time to select motors and other mechanical parts and create parts lists, drawings, operations manuals and so on.

Choosing a oyostepper' linear stepper motor actuator not only provides quiet and smooth working state, but also helps engineers to provide additional benefits in the early stage of design.

IMPROVE DESIGN EFFICIENCY
linear stepper motor efficientcy
The main characteristic of automation equipment is to realize a series of basic operations such as “transmission” and “push”. In other words, you can directly select the linear stepper motors to design automation equipment, do not need to choose other drive source device, simplify the design process. Combined with the oyostepper.com’ intelligent stepper drivers, linear stepper motors can be programmed with multiple stopping points to meet the requirements of multi-station automation design. The motions are very stable when operated, even at low speeds.​

SMALL SIZE
linear stpper motor small size
The linear stepper motors is compact in structure and the minimum size is NEMA8 series, which is convenient for overall design. The motors can directly connect with the cantilever mechanism, which saves the installation space of the coupling. It makes the mechanism exquisite and simple, without intermediate transmission link, and ensures higher precision, higher efficiency and longer life.​

HIGH PRECISION
linear stepper motor high precision
Linear stepper motors adopts high-precision screw drive, the screw is made by rolling processing molding one time, the minimum linear travel per step up to 0.001524mm. In addition, it can be freely combined with the innovative Anti-backlash nuts to eliminate back clearance of transmission and achieve higher accuracy. ​

LONG LIFE
The linear stepper motors (external nut linear actuator, non captive linear actuator stepper motor)uses excellent structure design and professional motor manufacturing technology, as well as self-lubricating nuts material and high-quality screws processing technology, to provide a guarantee of high life. In fact, internal and customer test records show that some linear motors have been running continuously for more than 6,000 miles.

https://www.mapquest.com/my-maps/9472c919-db26-4d8f-b167-fece47265575
https://www.houzz.com/hznb/professionals/handyman/oyostepper-pfvwus-pf~851041382?

lundi 16 décembre 2019

Tips on How to Choose Stepper Motors for Linear Motion

Motors must accelerate loads while overcoming system friction and gravity without overheating. Here, we outline a step-by-step process for picking a motor size that’s up to the task. Key points: First define the application. Then pick the motor technology and size and go from there. Calculate velocity, reflected inertia, and reflected load at the linear actuator stepper motor input. The RMS torque requirement predicts whether the motor will work. The approach outlined here is a first-approximation analysis.

The easiest way to design a linear-motion system is to add components one by one. Then, step-by-step calculations relate input to power dissipated moving a load in a specific amount of time.Linear systems drive everything from inexpensive seat movers in passenger vehicles to precision laser cutters and CNC machines. All move loads through a linear distance in a specific amount of time.


The second and third steps of the approach outlined here are to choose the motor type and size.

One approach for designing a linear system is to list basic requirements, add components one by one, and define every force interaction along the way.

Define the problem
To begin a linear design, determine the mass of what moves and how fast it goes from A to B. We work in SI units, as they eliminate multiple conversion constants and can always convert back into English units. For example, assume we’re choosing a motor for a simple linear-rail mechanism that moves a load:

Load's mass = 9 kg

Mass orientation: Vertical

A-to-B move distance and time = 200 mm in 1.0 sec

Dwell time = 0.5 sec

Move profile = 1/3-1/3-1/3  trapezoid–controlled acceleration and deceleration

Rotary-to-linear conversion = TFE-coated leadscrew Ø8 mm and 275-mm long

Load support: Linear ball rail and TFE-coated guide rails with a friction coefficient μ = 0.01

Overall size: Limited to the smallest volume possible

Drive architecture: Must be simple, as this is a cost-sensitive application

Drive control: Four-quadrant operation with encoder feedback

Drive power supply = 32 Vdc, 3.5 Arms, 5.0 Apeak maximum output

Worst-case ambient temperature = 30°C

Because force = ma (where a = acceleration due to gravity = 9.81 m/sec2), the 9-kg mass lifted against gravity requires a force of 88 N.

Sizing: Just the beginning
This article explains how to size a motor for a relatively simple single-axis linear-motion application. What don’t we cover here?

Sizing motors for complex designs. The motor-sizing principles we outline are applicable to X-Y tables and multiaxis pick-and-place machines. However, every axis in these designs requires independent analysis of load demands.

Choosing a safety factor so the machine lasts for its intended life. A design’s number of useful cycles depends on motor size, as well as the machine’s mechanical elements including the gearbox and leadscrew assembly.

Accounting for positioning accuracy, resolution, repeatability, maximum roll, pitch, and yaw. Only linear-motion systems that account for these fully meet application requirements.

1. How much power is needed to move the load in the required time?

Calculating minimum power output to translate the load provides a starting point for specifying the rest of the system's components. For our example, this is the average power needed to lift the 9 kg from A to B in 1 sec.

Machinedesign Com Sites Machinedesign com Files Uploads 2013 08 11372 Ee Eq1

where P = power, W; F = force, N; S = linear distance, m; and t = time, sec.

Note that power calculated here is less than peak power (or instantaneous power during the move profile) to accelerate and decelerate. Likewise, power calculated here doesn’t factor in extra power to overcome system losses such as friction. We’ll calculate the motor-shaft power for that in a later step.

Pick the motor
2. What motor technology is best for this application?

As outlined in our original parameters, the final design must be inexpensive and have simple drive architecture. Stepper motors satisfy both of these requirements. However, minimizing this machine’s overall volume is also important, so a stepper isn’t recommended: The 17.64-W minimum power requirement at the load (not including system losses and instantaneous peak power) would necessitate a large stepper. A brushless motor solves the problem of design footprint, but adds cost and complicates the drive architecture.

The third option — a dc-brush gearmotor with an in-line planetary gearhead — provides a small footprint, simplified drive, and relatively low cost. Adding a leadscrew for rotary-to-linear conversion keeps gearmotor output speed at around 1,000 rpm, which reduces generated heat at the leadscrew and nut-thread interface.

Gearmotor output
3. What’s the velocity, reflected inertia, and reflected load at the gearmotor output shaft (acting as the leadscrew input)?

Step one: Calculate the peak linear velocity of the application with its 1/3-1/3-1/3 motion profile:

Machinedesign Com Sites Machinedesign com Files Uploads 2013 08 11372 Ee Eq2


where vpk = peak linear velocity, m/sec.

Step two: Calculate the minimum pitch needed to keep the leadscrew speed at about 1,000 rpm:

Machinedesign Com Sites Machinedesign com Files Uploads 2013 08 11372 Ee Eq3

where pmin = minimum leadscrew pitch, m.

For one typical product, the closest pitch in an 8-mm screw diameter is 20.32 mm.

Step three: Calculate the peak shaft speed of the leadscrew (in rad/sec) for a linear velocity of 0.3 m/sec:

Machinedesign Com Sites Machinedesign com Files Uploads 2013 08 11372 Ee Eq4

The leadscrew for stepper motor we select is TFE coated, 275-mm long, 8 mm in diameter with a 20.32-mm pitch, and paired with a freewheeling nut. Assume the leadscrew efficiency, ηs, is 86% and its inertia, Js, is 38.8 × 10⁻⁷ kg-m2.

Step four: Determine the total reflected inertia, JT, back from the load to the leadscrew shaft:

Machinedesign Com Sites Machinedesign com Files Uploads 2013 08 11372 Ee Eq5

where JL = reflected load inertia, kg-m2; m = mass, kg; and p = leadscrew pitch, m.

Step five: Determine the shaft torque needed to accelerate the load inertia Ta:

http://obd2ware.soup.io/post/677298698/Power-Off-Brakes-for-NEMA-17-and
http://blog.qooza.hk/ytobd215?eid=29195915

vendredi 13 décembre 2019

How Do Brushless BLDC Motors Work?

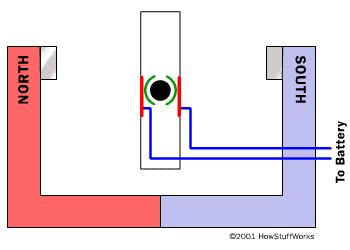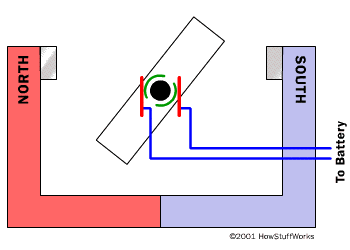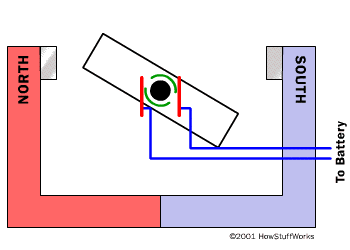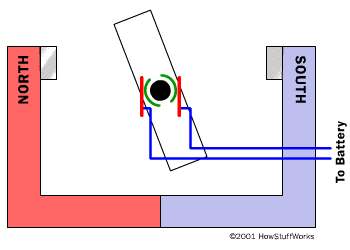
The article How Electric Motors Work explains how brushed motors work. In a typical brushless DC motor, there are permanent magnets on the outside and a spinning armature on the inside. The permanent magnets are stationary, so they are called the stator. The armature rotates, so it is called the rotor.


The armature contains an electromagnet. When you run electricity into this electromagnet, it creates a magnetic field in the armature that attracts and repels the magnets in the stator. So the armature spins through 180 degrees. To keep it spinning, you have to change the poles of the electromagnet. The brushes handle this change in polarity. They make contact with two spinning electrodes attached to the armature and flip the magnetic polarity of the electromagnet as it spins.

This setup works and is simple and cheap to manufacture, but it has a lot of problems:

The brushes eventually wear out.
Because the brushes are making/breaking connections, you get sparking and electrical noi
The brushes limit the maximum speed of the motor.
Having the electromagnet in the center of the motor makes it harder to cool.
The use of brushes puts a limit on how many poles the armature can have.
With the advent of cheap computers and power transistors, it became possible to "turn the motor inside out" and eliminate the brushes. In a brushless DC motor (BLDC), you put the permanent magnets on the rotor and you move the electromagnets to the stator. Then you use a computer (connected to high-power transistors) to charge up the electromagnets as the shaft turns. This system has all sorts of advantages:

Because a computer controls the motor instead of mechanical brushes, it's more precise. The computer can also factor the speed of the motor into the equation. This makes brushless motors more efficient.
There is no sparking and much less electrical noise.
There are no brushes to wear out.
With the electromagnets on the stator, they are very easy to cool.
You can have a lot of electromagnets on the stator for more precise control.
The only disadvantage of a brushless motor is its higher initial cost, but you can often recover that cost through the greater efficiency over the life of the motor.

For more information on brushless motors, check out the links following:https://www.oyostepper.com

Source:https://www.oyostepper.com/article-1103-How-Do-Brushless-BLDC-Motors-Work.html

What should take into considerations when choosing stepper motor

Number of wires (unipolar/bipolar)
The Duet boards use bipolar stepper motor drivers. This means you can use stepper motors suitable for bipolar drive, which have 4, 6 or 8 wires. You cannot use motors with 5 wires, because those are intended to be driven in unipolar stepper mode only. (Some unipolar motors can be made into bipolar motors by cutting a trace on a circuit board.)

Rated current

This is the maximum current you may pass through both windings at the same time. The maximum current through one winding (which is what really matters when using microstepping) is rarely quoted and will be a little higher. However, even with one winding driven at the quoted rated current, the motor will get very hot. So the usual practice is to set the motor current to no more than about 85% of the rated current. Therefore, to get maximum torque out of your motors without overheating them, you should choose motors with a current rating no more than 25% higher than the recommended maximum stepper driver current. This gives:

Holding torque

This is the maximum torque that the motor can provide with both windings energised at full current before it starts jumping steps. The holding torque with one winding energised at the rated current is about 1/sqrt(2) times that. The torque is proportional to current (except at very low currents), so for example if you set the drivers to 85% of the motor rated current, then the maximum torque will be 85% * 0.707 = 60% of the specified holding torque.
Size
There are two relevant sizes: the Nema size number and the length. The Nema size number defines the square dimension of the body and the mounting hole positions. The most popular size for 3D printers is nema size 17 stepper motor, which has a body no more than 42.3mm square and fixing holes in a square of side 31mm.

Step angle

There are two common step angles: 0.9 and 1.8 degrees per full step, corresponding to 400 and 200 steps/revolution. Most 3D printers use 1.8 deg/step motors.

Inductance

The inductance of the motor affects how fast the stepper motor driver can drive the motor before the torque drops off. If we temporarily ignore the back emf due to rotation (see later) and the rated motor voltage is much less than the driver supply voltage, then the maximum revs/second before torque drops off is.

Resistance and rated voltage

These are simply the resistance per phase, and the voltage drop across each phase when the motor is stationary and the phase is passing its rated current (which is the produce of the resistance and the rated current). These are unimportant, except that the rated voltage should be well below the power supply voltage to the stepper drivers.

Back emf due to rotation

When a stepper motor rotates it produces a back emf. At the ideal zero lag angle, this is 90 degrees out of phase with the driving voltage, and in phase with the back emf due to inductance. When the motor is producing maximum torque and is on the verge of skipping a step, it is in phase with the current.
About the Author
Established in 2010, Oyostepper.com is a professional stepper motor online china supplier at competitive prices coupled with a fast efficient service.

mercredi 7 novembre 2018

The choices among DC motors with encoders, servo motors and stepper motors

With the increasing popularity of DIY projects such as quadcopters, CNC tables and 3D printers, many people are faced with the decision of which type of motor to use in their project. For applications that require precise control of the position of the motor, the common choices are DC motors with encoders, servo motors, and stepper motors.

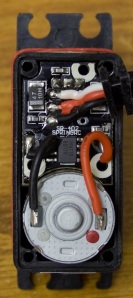
The insides of a typical servo motor. On the bottom, a 2-wire DC motor. On top, a circuit board that runs the control system and interprets servo commands.

A DC motor is the standard electric motor; it will spin as fast as it can with the DC power you provide it with. On its own, a DC motor has no position control. Most DC motor controllers allow you to change the duty cycle, a value from 0 to 100% that describes how much of your power supply is being made available to the motor.

A servo motor is just a DC motor with some upgrades: they typically have a gearbox to increase output torque, and they have a control system built right inside the motor’s casing. Since all of the control is built in, you can simply tell a servo to rotate to a specific angle, and it’ll try its best to move to that position. The downside to an integrated control system is that you usually can’t customize it in any way.

A best stepper motor uses alternating current through two separate coils to turn the rotor. I won’t go into the details, but the end result is that the motor moves in distinct “steps”, and the angle of these steps can be calculated from the step angle listed on the motor’s datasheet and the gearbox reduction ratio, if it has a gearbox. Since the motor turns a known amount each time a step is made, the position and velocity can be calculated.

1.8° NEMA 8 GEARED STEPPER MOTOR WITH PLANETARY GEARBOX
Four types of waveforms and sequences drive for stepper motors


lundi 5 novembre 2018

1.8° NEMA 8 GEARED STEPPER MOTOR WITH PLANETARY GEARBOX

Gear reduction stepper motor are perfect solutions for low speed and high torque positioning applications. GEMS provide NEMA size stepper motors that are paired with planetary gearbox and spur gearbox. Our design incorporates a square bodied motor and an round shape planetary stepper motor gearbox into a compact and cost-effective package. Our geared stepper motors are offered in six NEMA frame sizes (from NEMA 8 to geared stepper motor nema 23) and each NEMA size motor has an integrated stepper motor gearbox with a wide range of gear ratios (from 1:3.7 to 1:369) so as to deliver any desired torque and speed combinations for your applications. The dual shaft version is available for you to install the brake, shaft coupler or an encoder where you need to keep track of the shaft position. 8-lead motor is aslo available upon request for all possible wiring configurations: bipolar, unipolar, series, or parallel. For higher speed and better speed control capability, please check out our brushless gear motors.

1.8° NEMA 8 GEARED STEPPER MOTOR WITH PLANETARY GEARBOX
NEMA8 is our smallest size of geared stepper motor. The 22mm diameter planetary stepper motor gearbox has gear ratio from 1:3.7 to 1:369. The gearbox output torque is up to 143 oz-in (1 Nm)

1.8° NEMA 8 GEARED STEPPER MOTOR WITH PLANETARY GEARBOX

1.8° NEMA 8 GEARED STEPPER MOTOR WITH PLANETARY GEARBOX


vendredi 2 novembre 2018

Programming of stepping motor

The first script presented below is written for controlling our bipolar stepper motor using the Parallax Basic Stamp 2 microcontroller and the Board of education, and is best suited for demonstrating the principle of stepper motor control, however other hardware can be used with appropriate electronic modules. The nema 34stepper motor is assumed to be connected on pins 1 to 4, and 3 buttons, for changing the direction and type of sequence, are employed.

' {$STAMP BS2}
' {$PBASIC 2.5}

pulsetime CON 25 //experiment with this value in ms

buttons PIN 13
button1 PIN 14
button2 PIN 15

driveanddir VAR Nib
sel VAR Bit

driveanddir=0

DO //main loop start

SELECT driveanddir

IF (buttons=0) THEN
sel=0
IF (button1=1) AND (button2=0) THEN
driveanddir=0
ENDIF
ELSEIF (buttons=0) THEN
sel=0
IF (button1=0) AND (button2=1) THEN
driveanddir=1
ENDIF
ELSEIF (buttons=1) THEN
sel=1
IF (button1=0) AND (button2=1) THEN
driveanddir=2
ENDIF
ELSEIF (buttons=1) THEN
sel=1
IF (button1=0) AND (button2=1) THEN
driveanddir=3
ENDIF
ENDIF

CASE 0 //wave drive clockwise
DO
        driveanddir=0
        HIGH 1
        LOW 2
        LOW 3
        LOW 4
        PAUSE pulsetime
        LOW 1
        HIGH 2
        LOW 3
        LOW 4
        PAUSE pulsetime
        LOW 1
        LOW 2
        HIGH 3
        LOW 4
        PAUSE pulsetime
        LOW 1
        LOW 2
        LOW 3
        HIGH 4
        PAUSE pulsetime
LOOP UNTIL (button2=1) OR (sel=1)

CASE 1 //wave drive counterclockwise
DO
        driveanddir=1
        LOW 1
        LOW 2
        LOW 3
        HIGH 4
        PAUSE pulsetime
        LOW 1
        LOW 2
        HIGH 3
        LOW 4
        PAUSE pulsetime
        LOW 1
        HIGH 2
        LOW 3
        LOW 4
        PAUSE pulsetime
        HIGH 1
        LOW 2
        LOW 3
        LOW 4
        PAUSE pulsetime
LOOP UNTIL (button1=1) OR (sel=1)

CASE 2 //wave drive clockwise
DO
        driveanddir=2
        HIGH 1
        HIGH 2
        LOW 3
        LOW 4
        PAUSE pulsetime
        LOW 1
        HIGH 2
        HIGH 3
        LOW 4
        PAUSE pulsetime
        LOW 1
        LOW 2
        HIGH 3
        HIGH 4
        PAUSE pulsetime
        HIGH 1
        LOW 2
        LOW 3
        HIGH 4
        PAUSE pulsetime
LOOP UNTIL (button2=1) OR (sel=0)

CASE 3 //wave drive counterclockwise
DO
        driveanddir=3
        LOW 1
        LOW 2
        HIGH 3
        HIGH 4
        PAUSE pulsetime
        LOW 1
        HIGH 2
        HIGH 3
        LOW 4
        PAUSE pulsetime
        HIGH 1
        HIGH 2
        LOW 3
        LOW 4
        PAUSE pulsetime
        HIGH 1
        LOW 2
        LOW 3
        HIGH 4
        PAUSE pulsetime
LOOP UNTIL (button1=1) OR (sel=0)
ENDSELECT

Another scripting example, written in C++, for controlling the motor by using the now defunct parallel port is presented below. In this script the nema 42stepper motor is assumed to be connected on physical pins 2 to 5, or bits D0 to D3. A rapid example on how to calculate the output sent to the port:


Bit (pin) D0 (2) D1 (3) D2 (4) D3 (5) D4 (6) D5 (7) D6 (8) D7 (9)
Value (power of 2) 1 2 4 8 16 32 64 128


If you want to set a pin high, i.e. logic output 1, you need to send the corresponding value of the pin to the port. For instance for pin 5 the value to be sent is 8, for pin 3 the value is 2. If multiple pins are required to be set high, the sum of their corresponding values is sent tot the port. As an example, for pins 3 and 4 to be set high simultaneously, the value to be sent is 2+4=6, for pins 5 and 1 to be set high the value is 8+1=9.

#include
#include // ... all required libraries

#define PORT1o 0x378   //lpt output address -- check exact value in your settings
#define PORT1i PORT1o+1 //lpt input address

// ...... removed code used for defining variables and graphics drawing

//---functions defining control sequences for the motor, experiment with the delay value
void action1(void) // ----  wave drive clockwise
{
outportb(PORT1o,0);
outportb(PORT1o,1);
delay(50);
outportb(PORT1o,2);
delay(50);
outportb(PORT1o,4);
delay(50);
outportb(PORT1o,8);
};

void action2(void) // ----  wave drive conterclockwise
{
outportb(PORT1o,0);
outportb(PORT1o,8);
delay(500);
outportb(PORT1o,4);
delay(500);
outportb(PORT1o,2);
delay(500);
outportb(PORT1o,1);
};

void action3(void) // ----  full step clockwise
{
outportb(PORT1o,0);
outportb(PORT1o,3);
delay(500);
outportb(PORT1o,6);
delay(500);
outportb(PORT1o,12);
delay(500);
outportb(PORT1o,9);
};

void action4(void) // ----  full step counterclockwise
{
outportb(PORT1o,0);
outportb(PORT1o,9);
delay(500);
outportb(PORT1o,12);
delay(500);
outportb(PORT1o,6);
delay(500);
outportb(PORT1o,3);
};

// .... removed code

void main(void)  // main program loop

{
// ... removed code
}


The parallel port in brief
In a few words, the parallel port was initially designed for connecting printers to a computer but using it as a general I/O port for communicating with various other devices was pretty straight-forward, especially since IEEE 1284 standard defined the bidirectional implementation of the port. A variety of USB-to-parallel adapters are still available, a selection can be found here.

Parallel port DB-25 connector pinout
  • The data register is located at IOBaseAddress+0 (e.g. 0x378, if the LPT port address is 0x378);
  • The status register is located at IOBaseAddress+1 (e.g. 0x379) and can be accessed only through read operations;
  • The control register is located at IOBaseAddress+2 (e.g. 0x37a) and can be accessed either through write or read operations.
The lines are bidirectional and bits 4 and 5 are for internal control of the parallel interface, bit 4 validates interrupts and bit 5 validates data register input.

See more:
http://forum.cncprovn.com/threads/3967-CKD-Suu-tam-Arduino-closed-loop-Stepper-motor?p=151859

https://forum.vellemanprojects.eu/t/how-to-calculate-linear-motion-mm-with-a-stepper-motor/9660

mercredi 17 octobre 2018

Choosing on a stepper Motor for new printer

Hi,

I'm about to build my 3rd printer, even though I'm getting quite some experience already I'd like to hear some other advices regarding stepper motor.

I currently have a customized Prusa i3 printer and a customized Wilson II printer.

I currently run both printers with 0.9° step NEMA 17 motors (4200g.cm holding torque) for X and Y axis, I did run the i8 with 1.8° step NEMA 17 motors before, beside noise improvement I didn't see significant quality improvement.

Nema 17 Stepper Motor Bipolar 1.8 deg 13Ncm (18.4oz.in) 1A 3.5V 42x42x20mm 4 Wires (17HS08-1004S)

I have make numerous experiments, and I have made the following observations

Microstepping seems to have very little influence on print quality at 1/4, 1/8, 1/16 or 1/32 microsteps @ 0.9° or 1/8, 1/16, 1/32 @ 1.8° below that noise and vibration will affect the print.
the belts have a high impact on print quality, Neoprene/glass fiber belts (standard black belts) give much more vibrations than Polyurethane/steel core belts (White belts), however the later might have other troubles due to their rigidity and tension force necessary, these are the one I use on the Wilson II but I had to strongly reinforce the structure.
I have made movement tests up to 400mm/s with the Wilson II and I didn't notice losing steps (1/8 microstepping with 0.9° motors)

Now my new printer will be a different design, it'll be a 40x40x40cm 100% metal structure cube, printing platform will be moving on the Z axis and X carriage will be moving along Y axis (I considered a corexy but rejected it). Since I expect much higher rigidity than my current printers and I might want to have a heavier carriage (converting to CNC maybe), I'm thinking about using NEMA23 motors.

I have options to go with 1.8 or 0.9° motors, I can get 23HS7628 1.8°/step motors with 18.9Kg.cm holding torque , 23HS5628 1.8°/step motors with 12.6Kg.cm holding torque or 23HM1430 0.9°/step motors with 18Kg.cm holding torque. I would use TB6600 drivers at max 1/16 microstepping.

Since motor prices are quite different, I'm curious to have a second opinion. I think the 0.9° will probably not bring any quality improvement since the limitation will still be mecanical, and anyway since the motors are much stronger than nema17 I can go further in useful microstepping. I can get a sweet deal on the 12.6Kg.cm motors, and I'm hesitating with the 18.9Kg.cm ones (1.8°) which are 50% more expensive.

Or... should I just stay with cheap Nema17 motors?

Any thought?

samedi 13 octobre 2018

Control sequences of Stepping Motor

There are four types of waveforms, or sequences, through which stepper motors are driven. These are:

1. Wave drive;

2. Full step drive;

3. Half step drive;

4. Micro stepping – we will present this method and when it is employed in another article.

Wave drive
By using this method, a single phase of a nema 23 stepper motor is energized at a time. If we refer to figure 1 below we can see how a stepper motor is driven. We can observe that there are 3 phases (f=3), AA’, BB’ and CC’ and 2 teeth (z=2) North and South. The rotor will perform full steps, with the angle: Theta=360/(f*z)=60 degrees.

Control sequences of Stepping Motor


Full step drive
When the rotor of the motor depicted in figure 1 reaches position 3 we can see that the motor can also be driven by having two phases energized at the same time. The rotor will perform full steps, according to the formula above, aligning itself exactly in the middle of the angle between the stator poles, North and South. This drive method provides full torque of the motor.

The sequence will be:
AA’BB CC’
1 1 0
0 1 1
1 0 1
1 1 0


Half step drive
This method implies alternately powering either one phase or two phases at a time. The rotor will align itself either with stator poles, as in wave drive, or between them, as in full step drive. In this case the rotor will have 30 degree step angles.

The sequence is:

AA’BB  CC’
1 0 0
1 1 0
0 1 0
0 1 1
0 0 1
1 0 1
1 0 0

The direction of rotation in either case is determined on how the sequence is started. Sequences presented above assume clockwise rotation when applied starting from the first row and counter-clockwise rotation when started from back to front.

Control sequences of Stepping Motor


So, if we look at figure 1, depicting a 2-phase bipolar nema 42 stepper motor like the one we want to control, we can determine the control sequences for each method mentioned above. It can be observed that such a motor has 4 leads, corresponding to 4 pins of an output controller or interface. So the sequences will be:

• Wave drive: 1000 0100 0010 0001;

• Full step drive: 1100 0110 0011 1001;

• Half step drive: 1000 1100 0100 0110 0010 0011 0001 1001.

See more:
http://www.techsite.io/p/930613
https://yanguilai.katari.be/DcwbY8sy

jeudi 27 septembre 2018

Key features and shortcomings of Stepping Motor

Stepper motors have numerous advantages:

They ensure univocal conversion of control impulses to displacement and can be employed in open-loop control applications;
Have a wide range of control frequencies;
They provide precision and high resolution for positioning;
Allow for sudden starting, stopping or reversing without losing steps;
Can hold their position;
Are highly compatible with numerical control.
But they also have disadvantages like:

Key features and shortcomings of Stepping Motor


Fixed step value (angular displacement) for a given motor;
Relatively low speed;
Low torque;
Low power efficiency.
The characteristics of a stepper motor such as linear stepping motor or closed loop stepping motor are strongly dependent to load and type of the actuation mechanism it is employed in, so that:

A certain resolution for the complete actuation system is imposed;
Loads, forces or inertia must be reduced at the motor’s shaft;
A certain speed characteristic must be defined for accomplishing movement;
The ratio between loads reflected to the motor’s shaft and the actual torque of the motor must be kept in adequate limits.

jeudi 13 septembre 2018

Are all closed-loop stepper systems created equal?

How do I get the right control for my application?
Manufacturers apply the term "closed-loop stepper" to a wide array of controls. Here, we'll spell out how the three most common closed-loop stepper control schemes work and highlight their advantages and disadvantages.

Are all closed-loop stepper systems created equal?
No. Some manufacturers give the closed-loop stepper systems similar-sounding descriptions, which confuses the marketplace. As proof of the confusion, it's not uncommon that a designer requests one capability and actually needs another.

What are the most common closed-loop stepper systems?
There are three common types: Closed-loop stepper with step-loss compensation; closed-loop stepper with load position control; and closed-loop stepper servo control. Stepper-drive manufacturers call them all "closed loop" but the three have distinct functionalities.

What are the functionalities of these closed-loop stepper systems?
Closed-loop stepper with step-loss compensation is the most common type of closed-loop stepper control. The analog stepper driver operates as a micro-stepping drive and typically receives pulse and direction commands to move to the desired position. An encoder tracks shaft or load position. If lost steps are detected, a compensation algorithm inserts additional steps so that the motor shaft (or load) arrives at the desired position.

How do I get the right control for my application?
Machine builders must ask: Which control scheme does the application require? It may not be immediately apparent which control scheme the drive uses. Therefore, ask the manufacturer for details and review the documentation to ensure you get the right control scheme.

OYO High Torque Nema 34 Hybrid Stepper Motors TBNS001OP

mercredi 11 juillet 2018

Something about NEMA 23 Holding Brakes

OYOSTEPPER Products is pleased to announce the release of holding brakes for select step motors in the NEMA 23 frame size. These step motors provide additional functionality for applications which require holding torque to be maintained when power is removed from the motor.

Something about NEMA 23 Holding Brakes


Holding brakes offered by OYOSTEPPER are spring-set type brakes that must be powered by 24 volts DC to release the brake mechanism. This is commonly referred to as “power off” and is the preferred style for motion control applications. Controlling the brake is handled by a discrete output on the stepper drive or another controller like a PLC or motion controller. Many OYOSTEPPER drives offer outputs specifically designed to control the holding brake, such that the brake will be automatically engaged whenever the motor is unpowered (and automatically disengaged when the motor is powered or moving).

This initial offering of holding brakes for step motors is available as an option on the following most popular NEMA 23 frame step motors. Click to view specifications and pricing:

HT23-594B
HT23-598B
HT23-601B
HT23-603B
A common application for holding stepping motor brake is one in which a belt drive linear actuator is mounted vertically. When power is removed from the motor the belt and load can drop, potentially causing harm to the machine and/or human operators. Holding brakes can help to alleviate this unsafe condition by automatically holding the motor and load in position even when all power has been removed from the motor.

jeudi 7 juin 2018

Basics of Stepper Motors You Should Know

Operation & Structure
A stepper motor rotates with a fixed step angle, just like the second hand of a clock. Highly accurate positioning can be performed with open-loop control thanks to the mechanical structure within the motor.

Stepper Motor Operation Structure

Accurate Positioning (Number of Steps)
While having full control of rotation and speed, the simple structure of stepper motors is achieved without using electrical components, such as an encoder within the motor. For this reason, stepper motors are very robust and have high reliability with very few failures. As for stopping accuracy, ±0.05° (without cumulative pitch errors) is very accurate. Because positioning of stepper motors is performed by open-loop control and operated by the magnetized stator and magnetic rotor with small teeth, stepper motors have a higher follow-up mechanism toward commands than that of servo motors. Also, no hunting occurs when stopping stepper motors. They are also excellent in belt drives, which have low rigidity.


Useful for Speed Control and Position Control
When pulses are input to a driver through a pulse generator, stepper motors position according to the number of input pulses. The basic step angle of 5-phase stepper motors is 0.72° and 1.8° stepper motor for 2-phase motors. The rotating speed of the stepper motor is determined by the speed of the pulse frequency (Hz) given to the driver, and it is possible to freely change the motor rotation by simply changing the number of input pulses or frequencies to the driver. Stepper motors not only serve as position control motors, but also as speed control motors with high synchronization.


Stepper Motors Uses:
• High frequency, repetitive positioning of fixed step angles
• Positioning that requires long stopping time due to width adjustment, etc.
• Fluctuating loads and changing rigidity
• Positioning that divides 1 cycle
• Motor shafts that requires synchronous operation

See more:https://www.oyostepper.com/

lundi 7 mai 2018

The Motor Encoder: When Closed Loop Control is Essential

An stepper motor encoder for sale is a rotary device that can be mounted onto an electric motor. It provides closed loop feedback signals, tracking the motor shaft’s position, speed, or both.

The Motor Encoder: When Closed Loop Control is Essential


At first, this functionality might seem redundant. Isn’t precision control essentially what the stepper does on its own? The answer, it seems, is yes and no. Recent research has shown that the apparently “unnecessary” guidance provided by the encoder can have a powerful impact on how well a stepper motor works.

Motion controller brand Galil conducted a series of side by side tests between open and closed loop stepper motor systems. Their team discovered that the addition of an encoder could produce appreciable gains in major performance metrics.

Compared to the open loop system, the closed loop stepper motor offered:

Significantly improved velocity smoothness;

Reduced overall current consumption;

Higher torque at lower velocities than comparable three-phase brushless servo motors.

Galil's researchers determined that “dramatic” performance gains for stepper motors were possible by integrating a positional feedback device along with a two-phase brushless amplifier. Their testing methodology and results have been made public on their website.

These results are truly exciting news in the motion control world. Engineers at all levels can enhance stepper motors into even more powerful and economical solutions through the use of readily available encoder technologies.

KNOWLEDGE of CLOSED LOOP STEPPER SERVOS FOR EVERYONE

vendredi 4 mai 2018

Why stepper motors? What about other types of motors?

Choosing an appropriate stepper motor such as nema size 17 can be difficult and time consuming. This webpage is intended to help you easily and quickly select a good stepper motor for your project. There is a lot to cover, so consider this the first part in the series.

Why stepper motors?


Why stepper motors? What about other types of motors?
Stepper motors online are by far the most common types of motors used for CNC Machines. Stepper motors have a unique property that makes them particularly well suited for CNC motion. Each time a stepper motor receives a pulse, it only moves a certain amount. For a full step, this is usually 1.8 degrees and for a half-step this is usually 0.9 degrees. The reason this is important is because the computer running the motor doesn’t need to sense the actual position of the motor because the motor’s position can be calculated solely by how many pulses have been sent out.


Another possibility is to use PWM motors. These motors produce different torque depending on the duty cycle of a square wave signal it receives. However, a more complicated controller and an expensive quadrature encoder must be used to determine the current location of the motor at all times. This is a closed loop control system, where the system reacts based on position data which is detected through a sensor.

dimanche 27 décembre 2015

The Detail Function of SBB Key Programmer


In this modern society, we need to catch up with the pace of this high-tech world by

updating our knowledge. Have you noticed that the best  car key programmer –

SBB  Key Programmer has launched a new version into the market? If you’ve never

heard about this popular SBB Key Programmer V33 Version ever before, maybe

you really need to read this article carefully.Today tool supplier –obd2works.com

will help you and give you the detail information about those outstanding functions

of it.

Firstly, silica sbb transponder key machine is a new device used as a portable unit for

programming keys in immobilizer units on vehicles. And due to its integrated hardw

are, this best obdii–SBB needs no more than the OBDII cable provided to carry

out a wide range of functions. Secondly, programming new keys and reading keys from

immobilizers memory,deactivating keys no longer in the car owners possession are

available too. Operation by means of a menu guided programming and programming

new remote controls are its features, too. Moreover the software consists of full

database containing all the most important vehicle makes. What’s delighted, It can

supports many foreign languages, for this newest version, the supported languages

exactly includes Italian/German/French/English/Spanish/Greek/Portuguese/

Turkish/Russian. And the supported cars are Multi-brands.


More detail information can be found on obd2works.com,and there are more car diagn

ostic products you will be interested in.Any problem please feel free to contact us,we

will try our best to meet your demands.(digiprog3 4.94)

dimanche 27 septembre 2015

KWP2000 Plus fonctionne bien pour Peugeot 206 HDI

Je ai récemment acheté un kit d'un KWP2000 Plus pour se adapter à mon 2001 Peugeot 206 Turbo 90 ch 2.0HDI, afin de redéfinir pour augmenté ch. Commande passée le 26 Novembre, expédiée le lendemain et est arrivé à mon magasin ce matin.
KWP2000 Plus ECU REMAP Flasher Tunning
Je ai mis mes KWP2000 plus écus Remap Flasher de obd2warehouse.fr. Il est venu avec un mini CD, contenant son logiciel. Le vendeur a déclaré le logiciel doit être installé sur XP. Je ne ai aucun problème d'installation sur un ordinateur XP et je ai ensuite réussi à utiliser sur mon ordinateur portable Windows 7 en utilisant VM ainsi. Hooked on jusqu'à ma voiture quelques minutes après l'arrivée et reconfiguré mon écus. Il a travaillé comme il se doit.
Voici un processus rapide à propos de flashage écus avec KWP2000:
- Brancher le matériel sur le port USB de l'ordinateur portable et le port de diagnostic de la voiture
- Lancer le logiciel de communication
- Coupez le contact (et non moteur, juste l'allumage seulement)
- Sélectionnez le calculateur vous voulez lecture / écriture à partir d'une liste
- Sélectionnez des options supplémentaires (si nécessaire)
- Cliquez sur le bouton d'écriture et sélectionnez le fichier que vous voulez écrire
- Suivez les instructions à l'écran
- Couper le contact et attendre 10 secondes
- Fait.
http://www.obd2warehouse.fr/category-83-b0-Programmeur-De-Calculateur.html

dimanche 20 septembre 2015

Lexia3 Citroën / Peugeot diagnostic outil d'installation instruction

Nous savions que Lexia-3 est une interface de diagnostic professionnel Citroën et Peugeot, il est à la fois la fonction facile utiliser et puissant. De nombreux clients achètent cet outil de diagnostic de eobd2.fr et peuvent faire face certains installent des problèmes, laissez-moi vous dire les étapes de configuration pour éviter ces problèmes.

Lexia 3 Diagbox ou pp2000 V25 XS Evolution Citroen/Peugeot diagnostic tool Support Peugeot 307 avec Diagbox V7.57
À propos de Lexia-3 PP2000 Interface
http://www.obd2warehouse.fr/Lexia-3-Lexia-3-V47-PP2000-V25-for-Citroen-Peugeot-Diagnostic-Tools-646.html

Lexia-3 interface peut non seulement lire le code de défaut comme autre outil de scanner, mais aussi lire l'identification, auto-scan, vallées mesurées, test de l'actionneur, etc. compatible avec les voitures Citroën y compris: C1, C2, C3, C4, C6, C8 , C-CROSSER, NEMO, BERLINGO, JUMPY, JUMPER, AX, SAXO, BX et ainsi de suite, et il a également compatible avec la plupart des voitures Peugeot de 1995.

Eobd2.fr  Lexia3 PP2000 Citroen/Peugeot diagnostic interface de mise à jour maintenant vers la dernière version: Lexia-3: V46, PP2000: V23, multi-langue disponible.

Lexia3 Citroën / Peugeot outil de diagnostic PP2000 configuration instruction

1. Instruction avant l'installation:

PP2000 V21 est le logiciel pour Peugeot!

Cliquez sur 'InstPC' installer

Lexia3 V45 est le logiciel pour Citroën!

Cliquez sur 'Instlex3' installer

Se il vous plaît créer un fichier txt vide nommé 'version' dans C: \ avant l'installation du Lexia3.

2. étapes de configuration Instruction:

A. Installez le logiciel. Avant l'installation, le système de fenêtres doit être anglais, et jusqu'à ce que dans le choix de la langue lors de l'installation du logiciel, vous êtes libre de choisir votre langue maternelle.

B. Activation du logiciel.

Sous le fichier "LEXIA3_KEYGEN", il ya les images d'activation pour lexia3 et le fichier "PP2000_KEYGEN" contient les images d'activation pour PP2000.

Conseils:

1. Il faut code enregistré pour PP2000, mais aucun code inscrit pour lexia3, comme pour le code enregistré.

2. Pour les clients dont la langue maternelle ne est pas l'anglais, ce est ok, car il ya 20 sortes de langue pour Citroën et 26 sortes de langue pour Peugeot.

AVIS: Avant l'installation, vous devez fermer tous les logiciels anti-virus, pour empêcher les données de l'appareil est détruit par le logiciel anti-virus.

jeudi 13 août 2015

Lexia3 Citroën / Peugeot diagnostic outil d'installation instruction

Nous savions que Lexia-3 est une interface de diagnostic professionnel Citroën et Peugeot, il est à la fois la fonction facile utiliser et puissant. De nombreux clients achètent cet outil de diagnostic de obd2warehouse.fr et peuvent faire face certains installent des problèmes, laissez-moi vous dire les étapes de configuration pour éviter ces problèmes.
Lexia 3 V48 PP2000 Diagnostic Interface Complet Plus Lexia-3 30 pin câble (interface ronde)
À propos de Lexia-3 PP2000 Interface

Lexia-3 interface peut non seulement lire le code de défaut comme autre outil de scanner, mais aussi lire l'identification, auto-scan, vallées mesurées, test de l'actionneur, etc. compatible avec les voitures Citroën y compris: C1, C2, C3, C4, C6, C8 , C-CROSSER, NEMO, BERLINGO, JUMPY, JUMPER, AX, SAXO, BX et ainsi de suite, et il a également compatible avec la plupart des voitures Peugeot de 1995.

obd2warehouse.fr Lexia3 PP2000 Citroen/Peugeot diagnostic interface de mise à jour maintenant vers la dernière version: Lexia-3: V46, PP2000: V23, multi-langue disponible.

Lexia3 Citroën / Peugeot outil de diagnostic PP2000 configuration instruction

1. Instruction avant l'installation:

PP2000 V21 est le logiciel pour Peugeot!

Cliquez sur 'InstPC' installer

Lexia3 V45 est le logiciel pour Citroën!

Cliquez sur 'Instlex3' installer

Se il vous plaît créer un fichier txt vide nommé 'version' dans C: \ avant l'installation du Lexia3.

2. étapes de configuration Instruction:

A. Installez le logiciel. Avant l'installation, le système de fenêtres doit être anglais, et jusqu'à ce que dans le choix de la langue lors de l'installation du logiciel, vous êtes libre de choisir votre langue maternelle.

B. Activation du logiciel.

Sous le fichier "LEXIA3_KEYGEN", il ya les images d'activation pour lexia3 et le fichier "PP2000_KEYGEN" contient les images d'activation pour PP2000.

Conseils:

1. Il faut code enregistré pour PP2000, mais aucun code inscrit pour lexia3, comme pour le code enregistré.

2. Pour les clients dont la langue maternelle ne est pas l'anglais, ce est ok, car il ya 20 sortes de langue pour Citroën et 26 sortes de langue pour Peugeot.

AVIS: Avant l'installation, vous devez fermer tous les logiciels anti-virus, pour empêcher les données de l'appareil est détruit par le logiciel anti-virus.